Robot arm: linear rail and welding
An extra axis built from scratch, and robotic welding explained for operators.
01 About the project
Two pieces of work around a Fairino industrial robot arm.
The first is the firmware for a linear rail that carries the robot, a Fairino FR10. The rail works as the seventh axis: the arm moves itself along it to a new working position, which greatly extends the area it can serve.
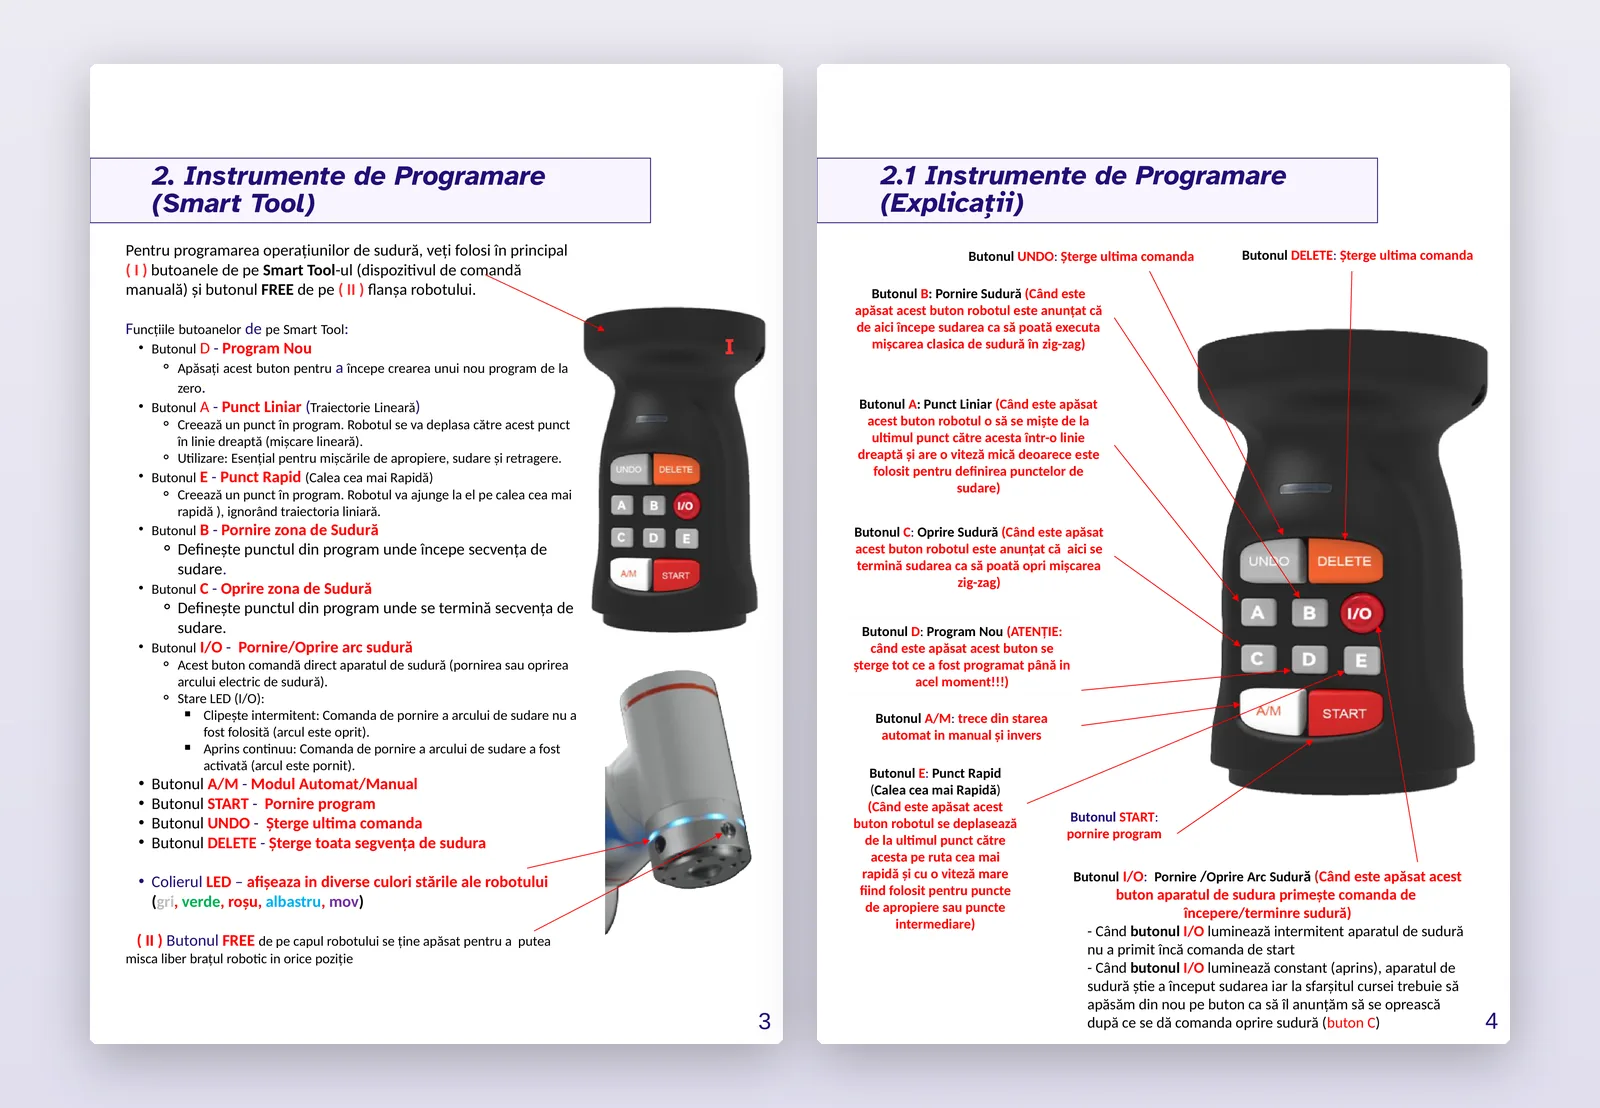
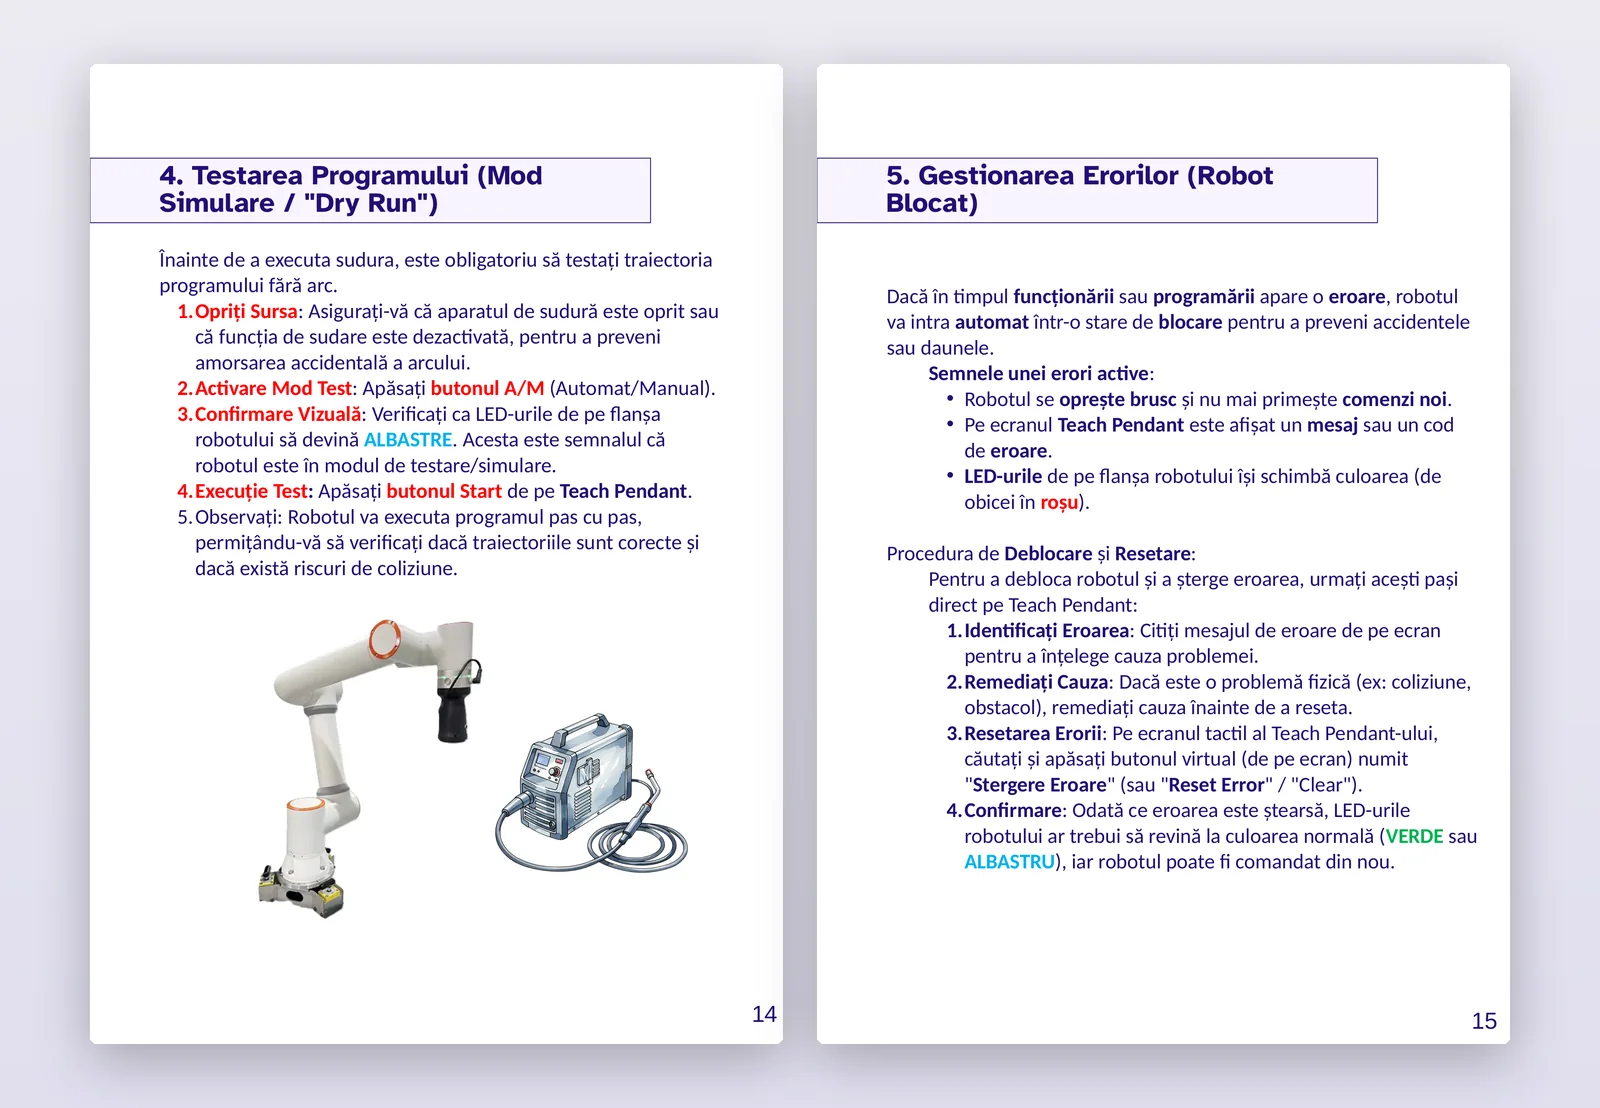
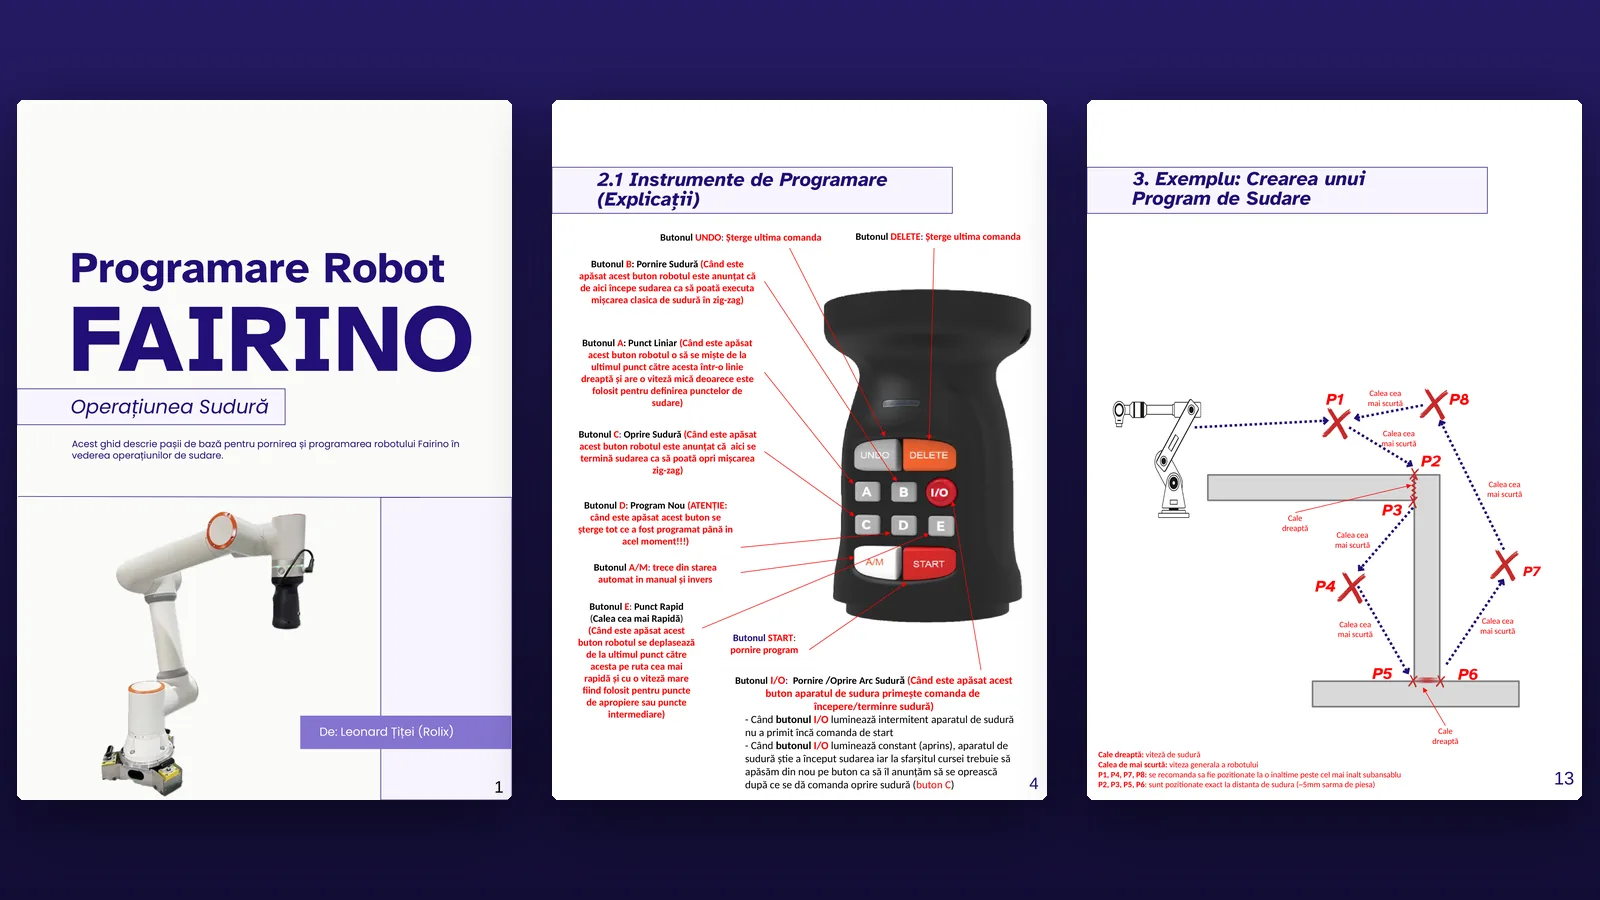
The second is robotic welding. I wrote a welding programming manual in Romanian, made for operators: how to start the robot, how to teach it a path by guiding it by hand, how to test the program without the arc and how to recover after an error.
02 My contribution
- 01
ESP32 controller (FreeRTOS, dual-core): it receives the target position from the robot over Modbus TCP and drives the servo drive over Modbus RTU (RS485).
- 02
Software position tracking that survives restarts, and limit switch configuration.
- 03
Wi-Fi web interface for tuning, testing and diagnostics.
- 04
A welding programming manual in Romanian: the Smart Tool buttons, the tool and workpiece coordinate systems, dry runs and error handling.
- 05
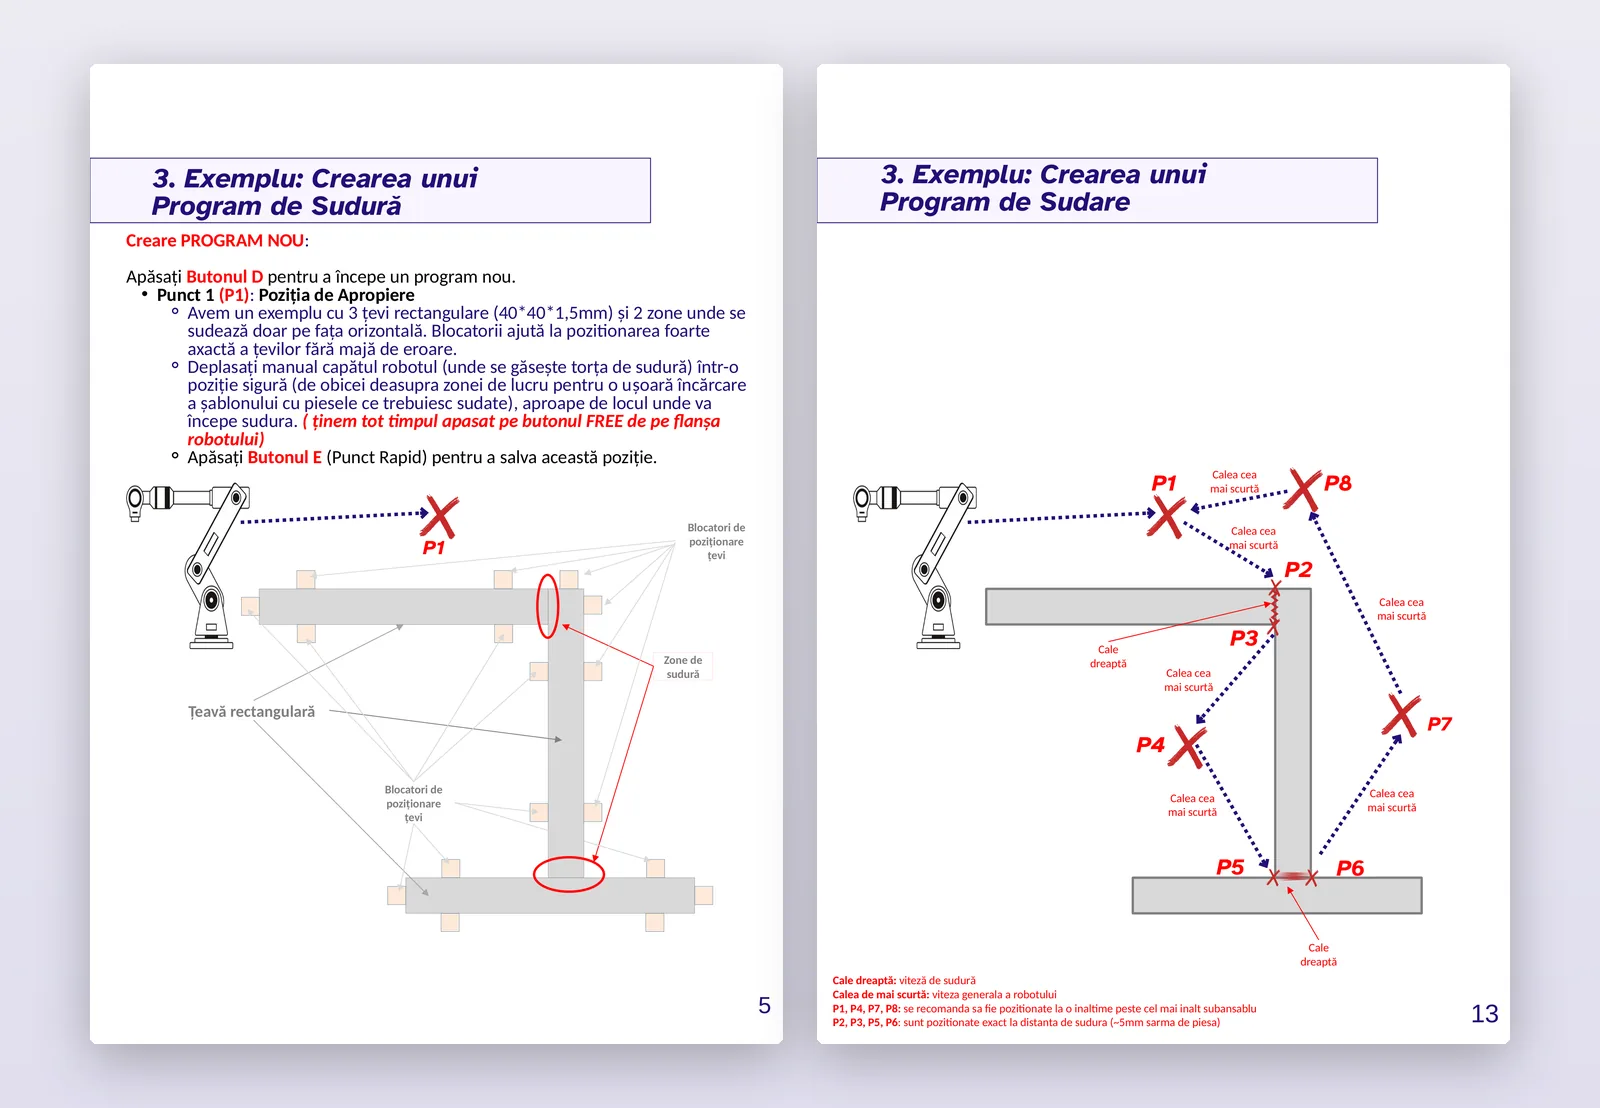
A complete example, drawn step by step: welding three 40×40 mm rectangular tubes, positioned in a jig with stops, using eight path points.
03 Tools