TES / Steinel
A robot that carries samples from the production line to the lab.
01 About the project
TES (Steinel Sample Transporter) is a mobile robot developed for the Steinel factory as a Lean Six Sigma improvement project. Quality-control operators used to carry samples by hand from the production lines to the AQL lab and back, many times per shift.
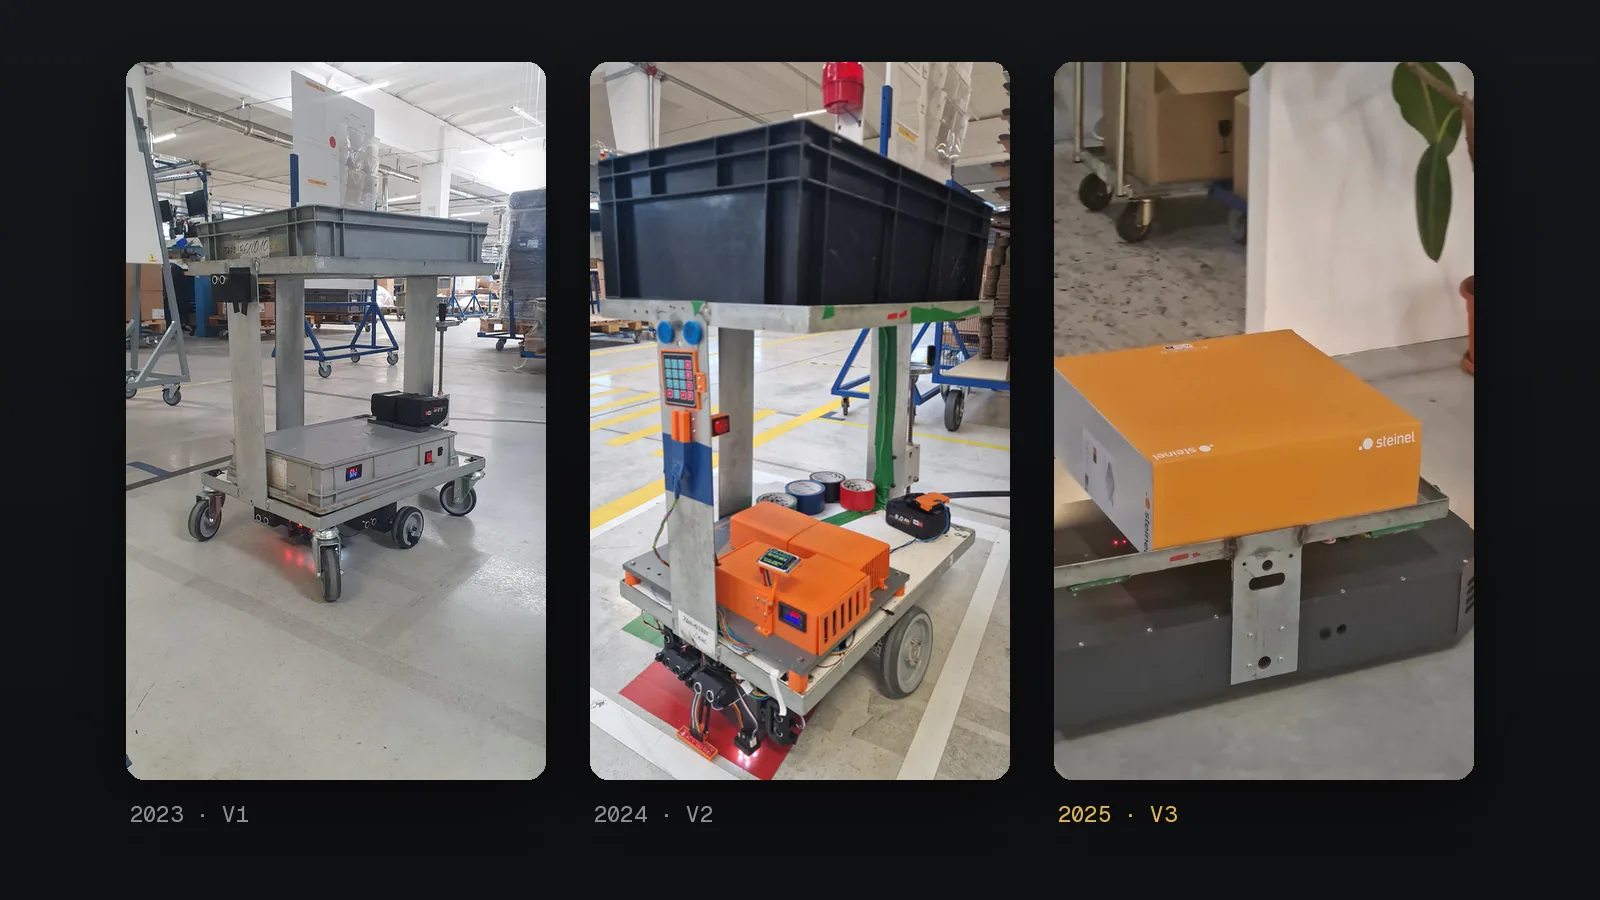
The robot takes over that trip: it is loaded at the line, drives to the lab on its own and comes back ready for the next job. It went through three versions between 2023 and 2025.
— The challenge
On one of the lines, measurements showed about 4 minutes lost on every trip — more than 70 hours a year on that route alone. Time that adds no value to the product, but could not be removed without changing the workflow.
02 My contribution
- 01
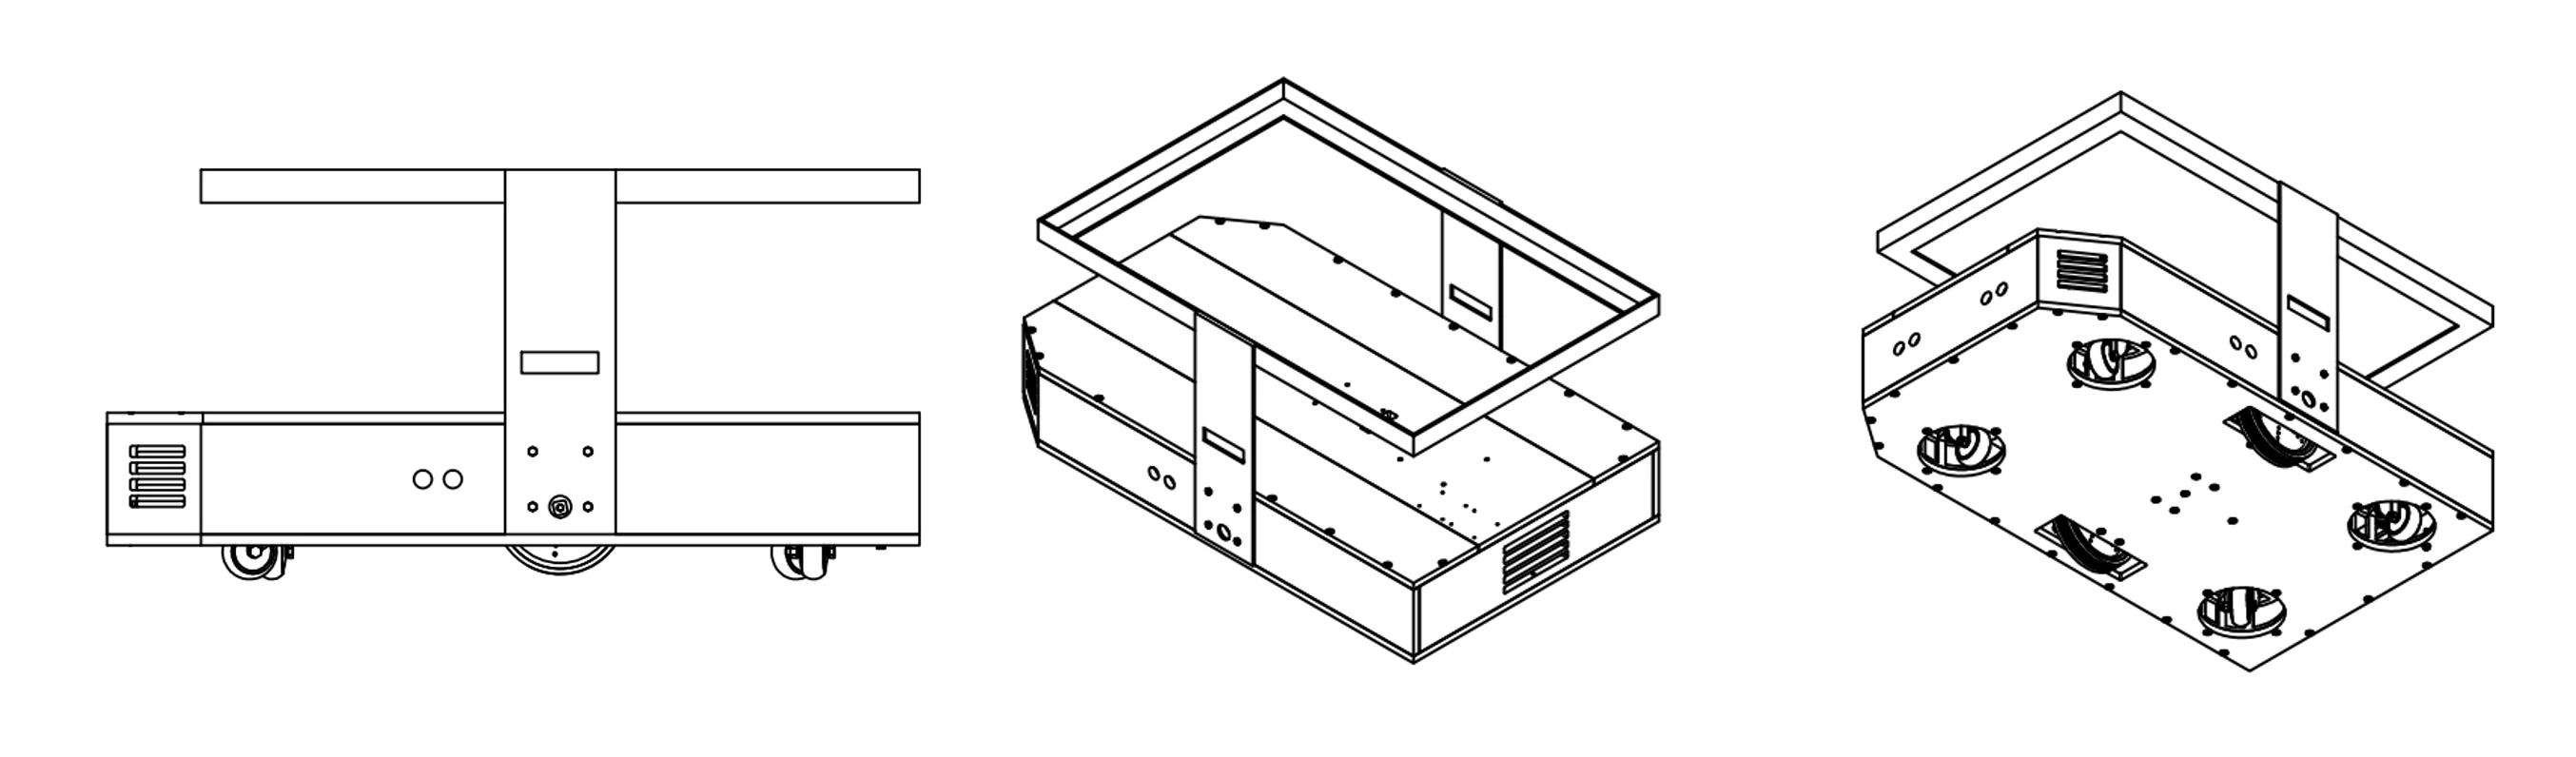
Three robot versions: from a cart with a lidar (2023) to a compact platform with its own enclosure and light signals (2025).
- 02
Autonomous navigation with ROS 2 on a Raspberry Pi 5: SLAM mapping, AMCL localisation and Nav2 path planning.
- 03
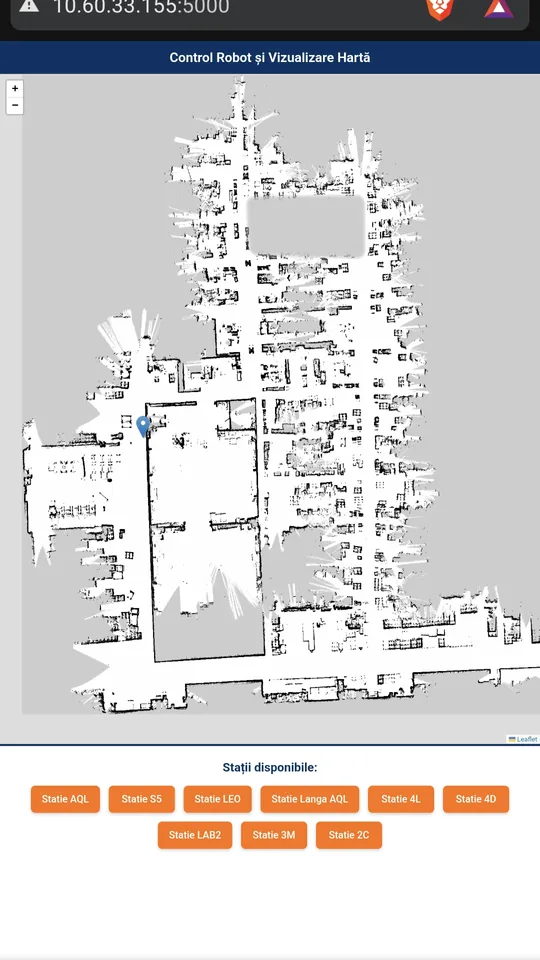
Phone control with the factory map and preset stations, plus a keypad, a screen and a remote on the robot.
- 04
Process mapping and planning of the route and loading stations, together with the production team.
— The outcome
On the line furthest from the lab, the robot removes the operator trips completely: it is loaded, leaves and comes back on its own. The tests also showed where the gain is small — on the nearby lines — which led to a proposal for a new workflow, where samples are picked up directly by the line operators.
03 Tools